Planetary Arm Tbot-ArmPX
Composed of planetary gear joint modules, 3~7 axes, bionic flexible arm, payload 2~10kg.

Tbot-ArmPX-A7

Tbot-ArmPX-P6

Lightweight integrated-drive arms for industry and education; bionic collaborative flexible exoskeleton robots — hollow design, high-speed closed loop, free joint combinations for rapid robot building.
Lightweight integrated-drive arms for industry and education; bionic collaborative flexible exoskeleton robots.
A hollow design suits multi-axis cobots; a high-speed closed loop gives more flexible control and higher performance; with free joint combinations and technical support, you can build fast.
Composed of planetary gear joint modules, 3~7 axes, bionic flexible arm, payload 2~10kg.
Composed of harmonic gear joint modules, 3~7 axes, bionic flexible arm, payload 2~10kg.


 Tobot Humanoid Robot Arm
Humanoid Robot
The arm used on humanoid robots, featuring planetary joint modules.
 Tobot Humanoid Robot Arm Teach & Execute
Humanoid Robot
The arm used on humanoid robots, featuring harmonic joint modules — teach & execute demo.
 Tobot Humanoid Robot Arm Motion Execution
Humanoid Robot
The arm used on humanoid robots, featuring harmonic joint modules — motion execution demo.
 Dual-arm robot arm motion demo
Factory Environment
Simulated automated operation of factory equipment, with press-button preparation and click-controlled processes
Servo modules feature a hollow design, ideal for 6-axis collaborative arms, with a high-speed closed-loop cycle for flexible control of arm rigidity and precision, delivering high-performance robot bodies for host systems.
Robots with different payloads use freely combinable joints, with body and software support so customers can quickly build their own robotic systems.

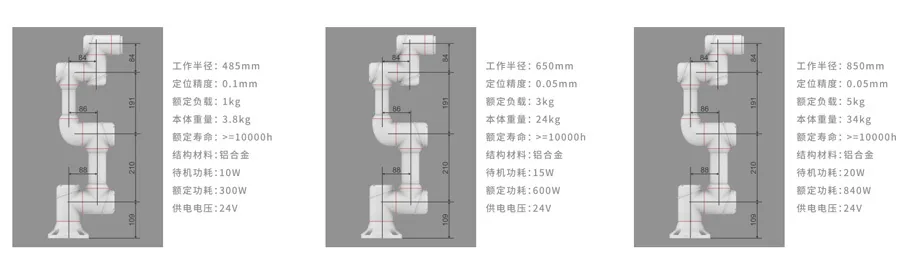
Servo modules integrate the drive, so the arm needs no traditional control cabinet; the host computer controls the arm directly via CANOPEN or ETHERCAT bus.
The arm body supports multiple controller options; customers can choose the control method to suit their application scenario.
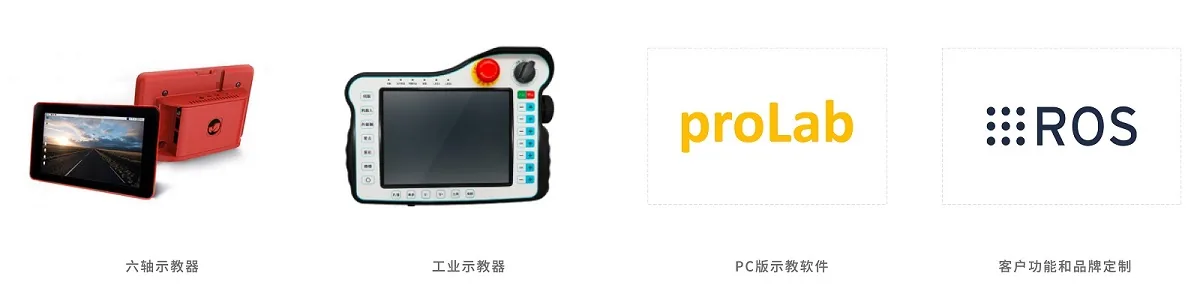
One-stop customization of appearance, structure, hardware, software and platform — from prototype validation to mass production.