Sensor Fusion
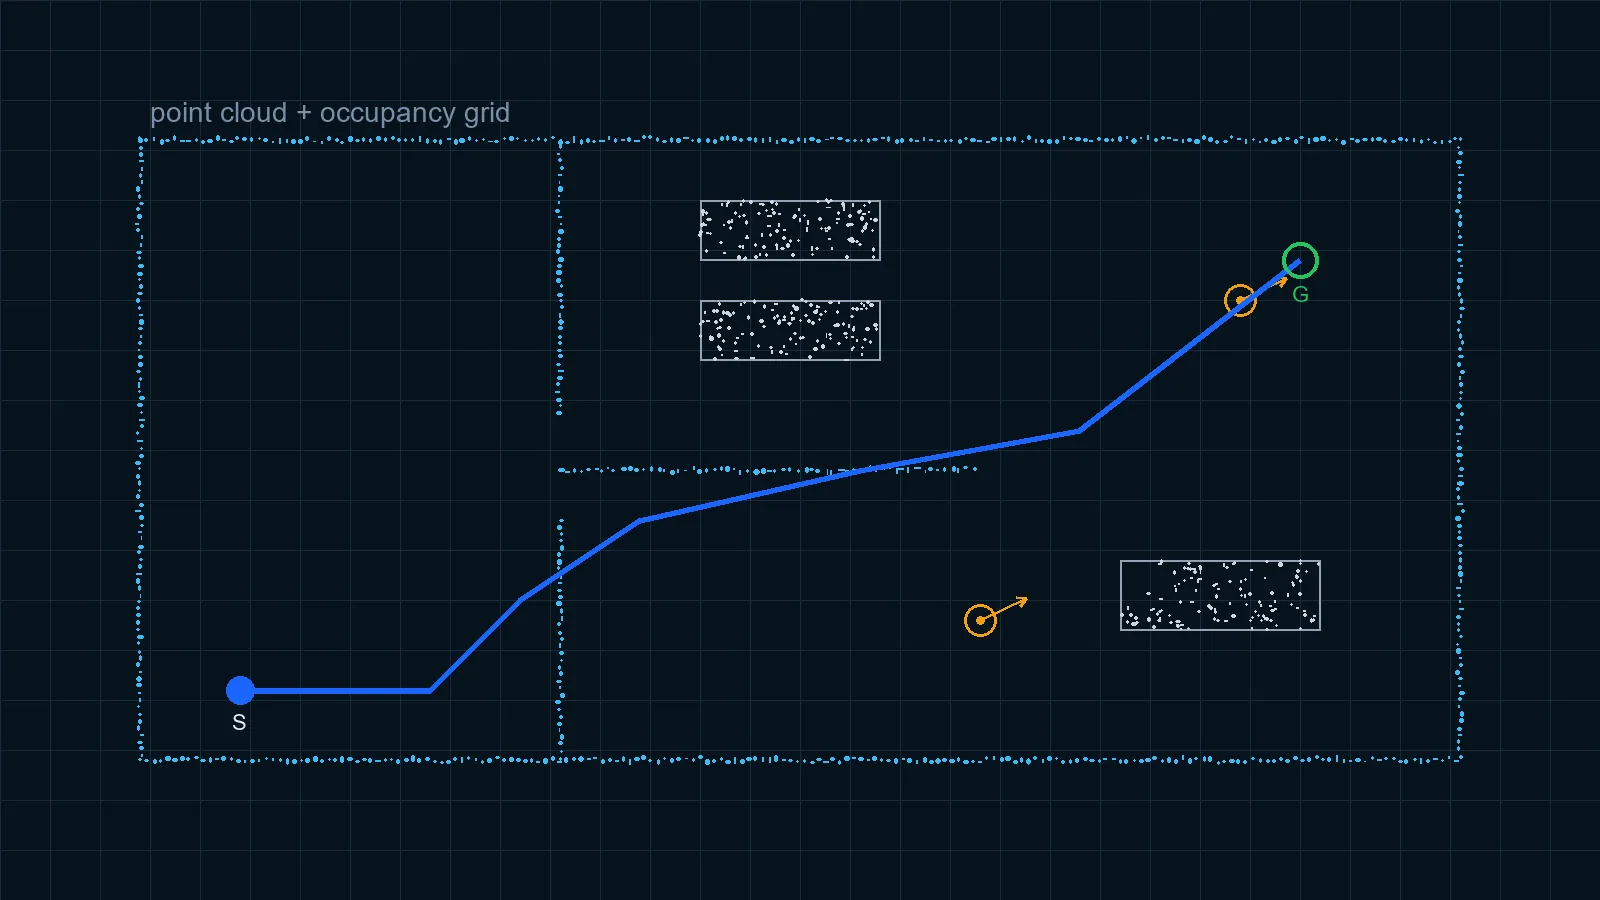
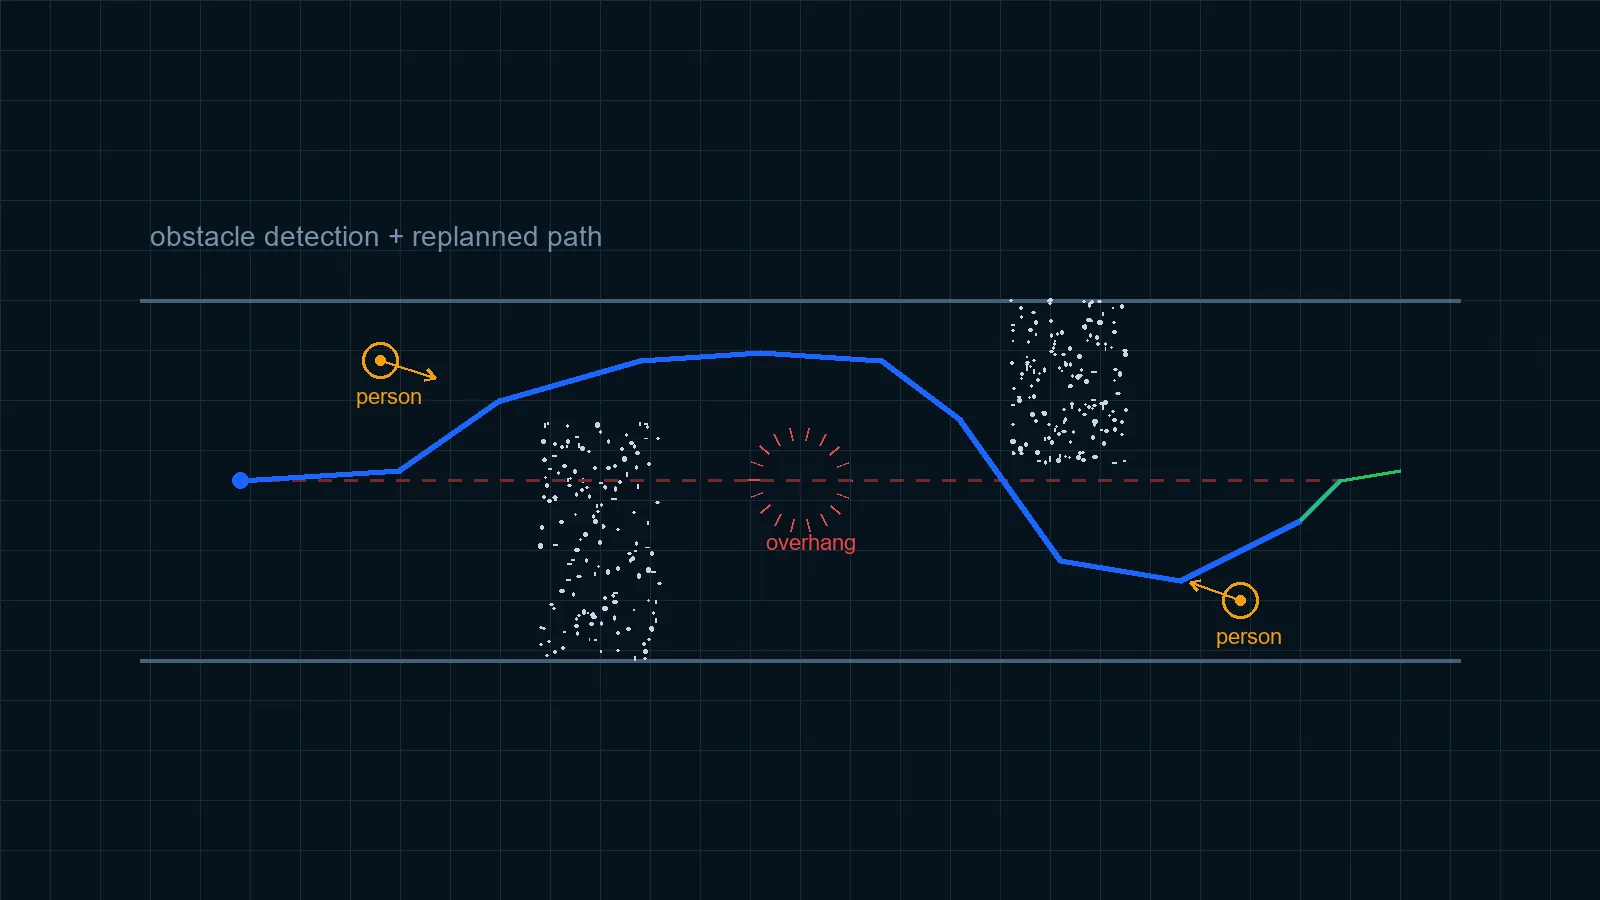
3D multi-line LiDAR as the primary sensor, optionally with front/rear dual LiDAR, depth cameras and ultrasonic radar for 360° stereo perception without blind spots; point-cloud pre-processing, ground segmentation and multi-target tracking output a stable traversable area.